Wireless Robot with Gripper Arm
A wireless controlled robot with a gripper arm, built for a student robotics course.
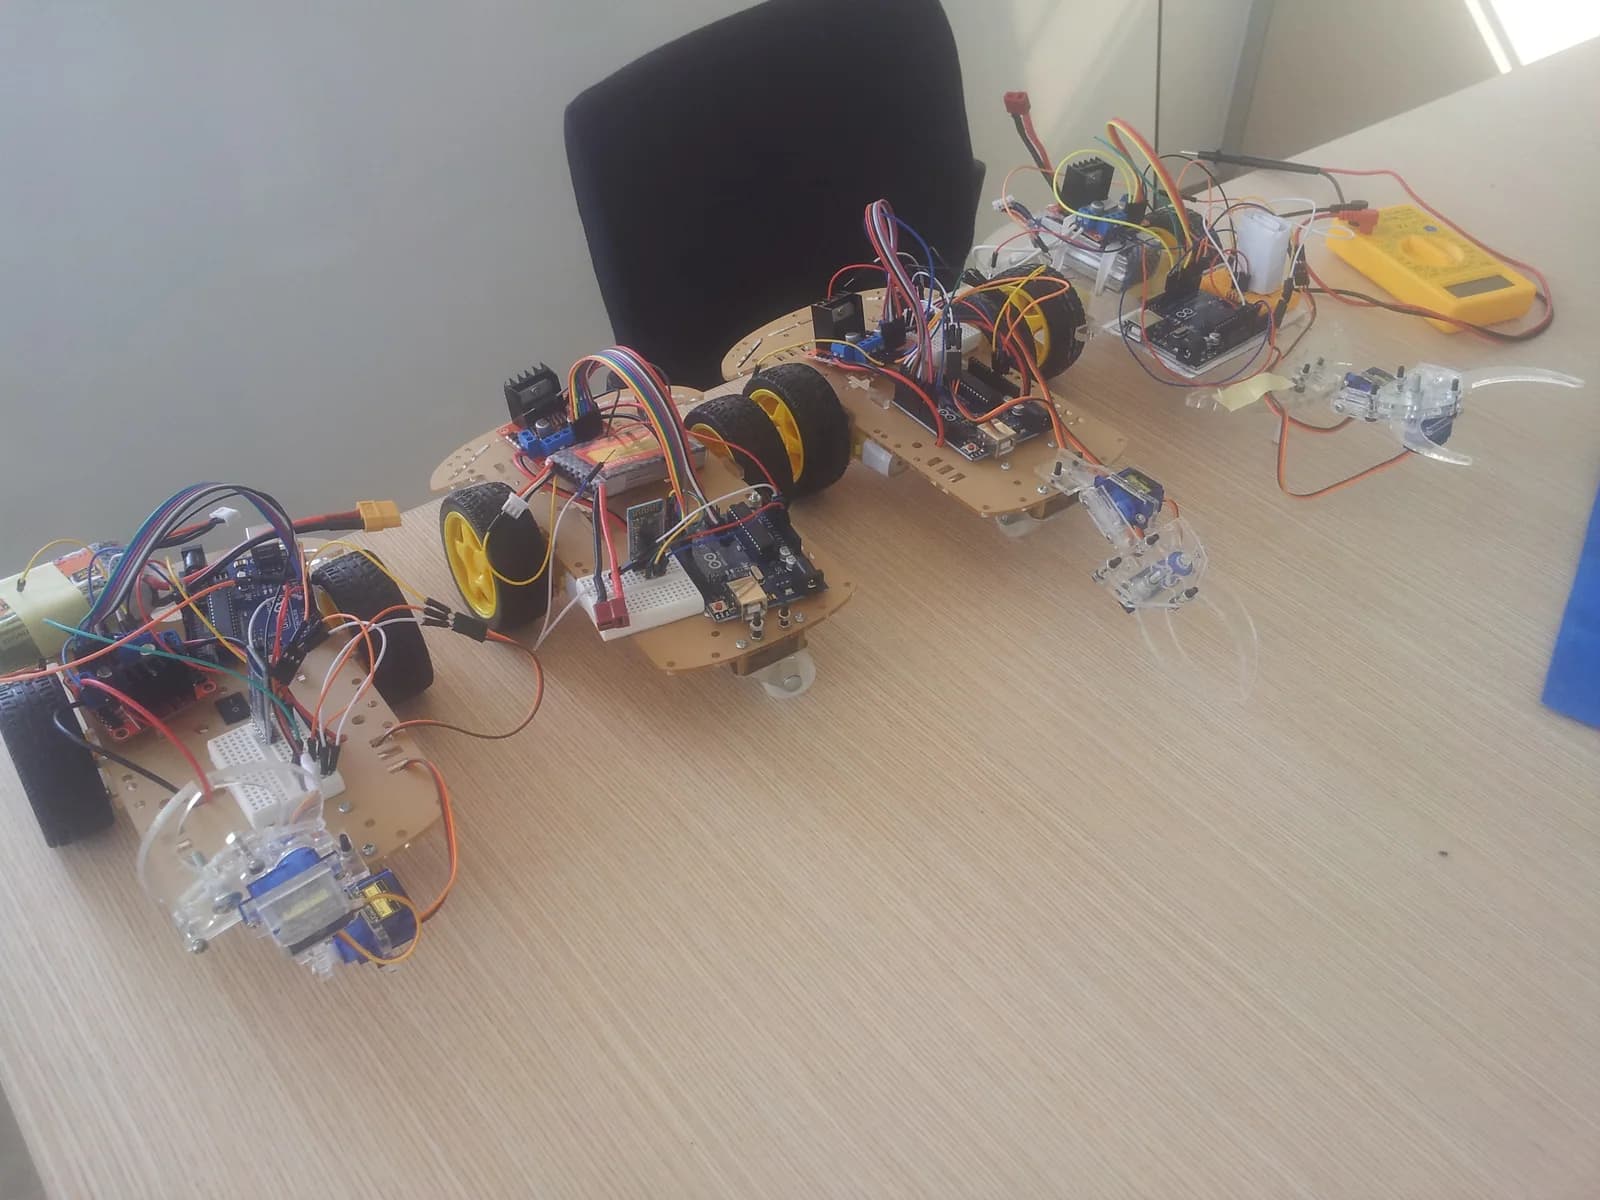
Designed and built a wireless controlled robot with a gripper arm: a differential drive chassis and a 2 DOF gripper in Fusion 360, Arduino firmware for the motors and the arm, and an Android app for driving it.
The chassis was planned for laser cut manufacturing. When custom manufacturing exceeded the available budget, the final robot used an accessible chassis while the arm, the firmware, and the control system were developed for the course.
The mechanical design
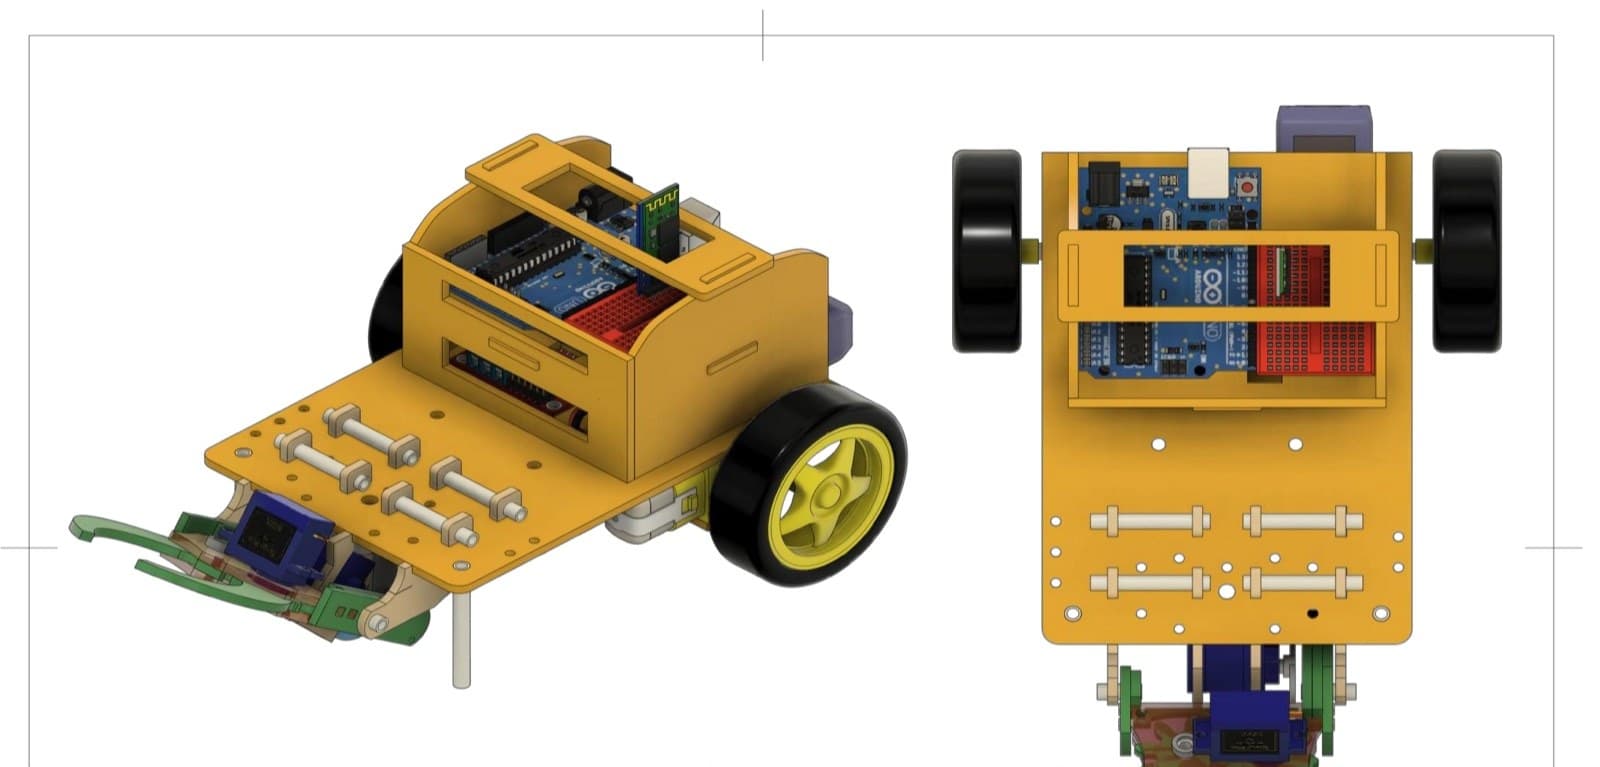
Designed a differential drive chassis and a 2 DOF gripper in Fusion 360, with the chassis plates planned for laser cut manufacturing. The drawing set covered the plates, the arm mounting, and the clearance the gripper needed in order to open.
Firmware and control
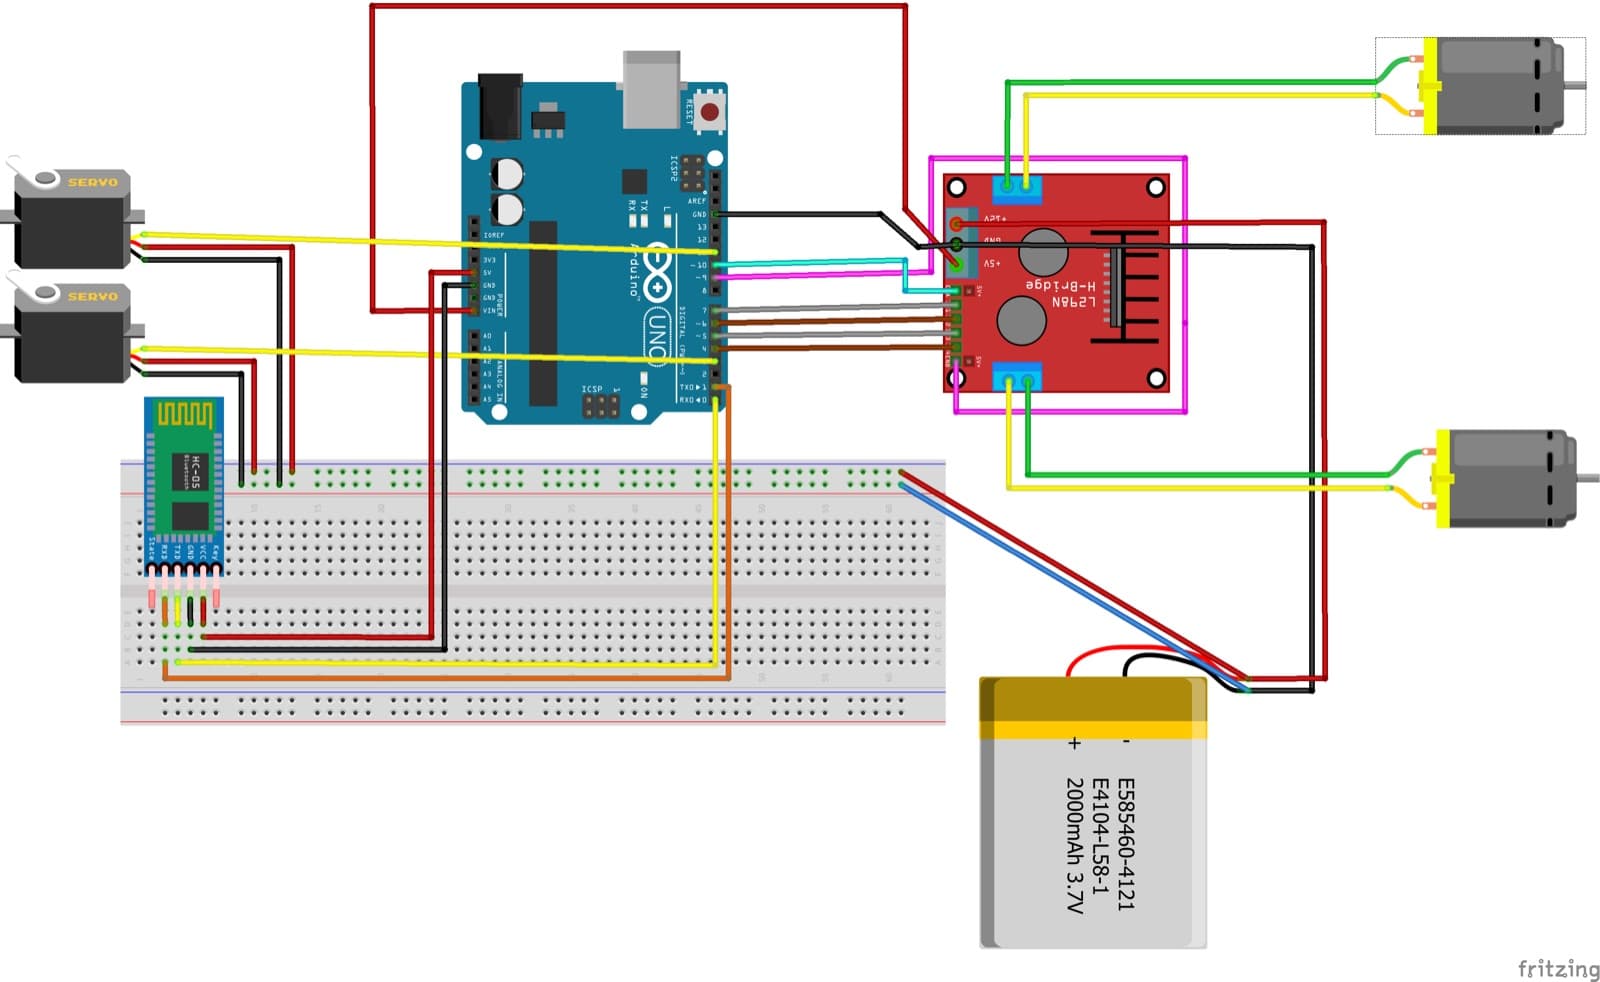
Arduino firmware drove the DC motors, the servo motors, and the Bluetooth serial link. An H bridge motor driver and a Bluetooth module were wired to the board so the robot could be driven from another device without a cable.
The Android controller
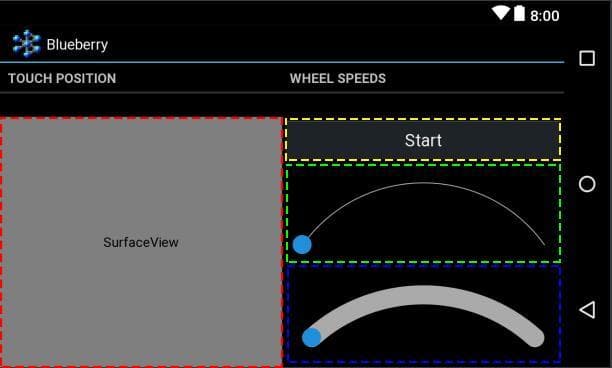
Built an Android app with a virtual joystick for driving and separate controls for lifting the arm and opening the gripper, so one person could operate the whole robot from a phone.
Built to be taught from
The robot had to be understandable to students, possible with available parts, and reliable enough to demonstrate in front of people. That constraint shaped every choice, from the chassis to the wiring.
selected tools
- Fusion 360
- Arduino
- C++
- Bluetooth
- Android
- Electronics
figures